


PIR Motion Sensor with ESP32 or ESP8266 for Alexa: HC-SR501, HC-SR505, AM312
In this section we’ll walk through creating a PIR Motion Sensor using ESP32, ESP8266 or Raspberry Pi Pico W and then view the motion changes via Alexa or SmartThings.
Prerequisites :
- ESP32, ESP8266 or Raspberry Pi Pico W x 1.
- HC-SR501, HC-SR505, Mini AM312, HC-SR312 x 1.
- Jumper Wires.
| PIR | Working voltage | Delay time | Blocking time | Trigger | Distance |
|---|---|---|---|---|---|
| HC-SR312 | 2.7-12V | 2 seconds | 2 seconds | Repeatable | 3-5 meters |
| HC-SR505 | 4.5-20V | 2 seconds | 2 seconds | Repeatable | 3 meters |
| HC-SR501 | 4.5-20V | Adjustable | Adjustable | Adjustable | 3 meters to 7 meters |
HC-SR501 vs HC-SR505 vs AM312 (HC-SR312): which one to choose?
The HC-SR312 is the mini PIR module built around the AM312 sensor, so the two names refer to the same part.
- HC-SR501: the largest module and the only one you can adjust. It has two potentiometers (sensitivity and time delay) and a jumper for single or repeatable trigger. Choose it when you need a longer range or want to tune the behaviour. It needs at least 4.5 V, so power it from 5V / VIN.
- HC-SR505: a small module with fixed settings. Nothing to adjust. It also needs at least 4.5 V.
- AM312 / HC-SR312: the smallest module, also with fixed settings. It runs from 2.7 V, so it can be powered directly from the 3.3V pin. This makes it the best fit for ESP32 / ESP8266 boards and battery powered projects.
All three have the same three pins: VCC, OUT and GND. The pin order is different on each module, so check the labels on the board before wiring. The same code works for all of them.
Quick introduction to PIR Motion Sensors
Passive infrared (PIR) motion sensors detect the presence of people or animals by measuring changes in infrared radiation. PIR sensors work by detecting the infrared radiation emitted by all objects that have a temperature above absolute zero. When a person or animal moves into the field of view of a PIR sensor, the sensor detects a change in the amount of infrared radiation and triggers an alarm or other output. PIR sensors are a versatile and cost-effective way to detect motion. They are easy to use and can be installed in a variety of locations.
The output of the PIR Motion Sensor is:
HIGHwhen a movement is detected.LOWwhen no movement is detected.
To get accurate measurements, wait for the PIR sensor to calibrate properly, this will normally take from 10 to 60 seconds after turning it on.
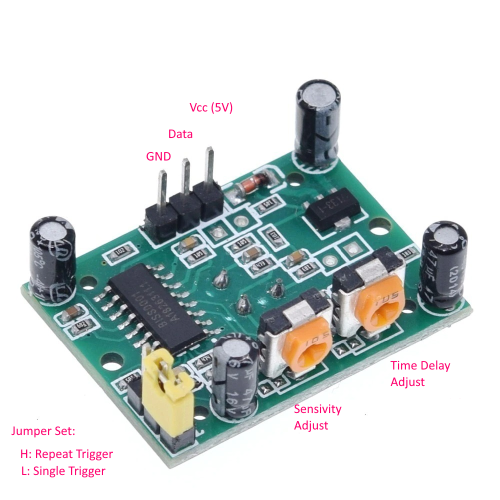
The HC-SR501 has adjustable configurations:
Sensitivity Adjustment
-
Measuring distance is between 3 and 7 meters.
-
Turning clockwise or right - Decreases the sensivity. Fully right upto 3 meters.
-
Counter Turning clockwise or left - Decreases the sensivity. Fully left about 7 meters.
Time-Delay Adjustment
-
Delay time that defines how long the output of the HC-SR501 stays
HIGHafter a motion is detected. It can be adjusted from 1 second to about 5 minutes. -
Turning clockwise or right - Increase the delay. Fully right upto 5 mins.
-
Counter Turning clockwise or left - Decreases the delay. Fully left about 3 seconds.
Jumper Set
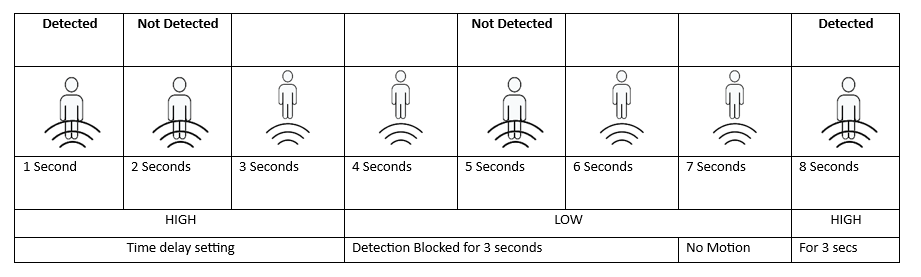
- Single Trigger Mode (L): Triggers a single motion. The time delay potentiometer determines how long the pin will stay
HIGH. Any further motion detection is blocked until turns toLOW.
Example: The motion detector’s time delay is set to 3 seconds, but it cannot detect motion for about 6 seconds after detecting motion.
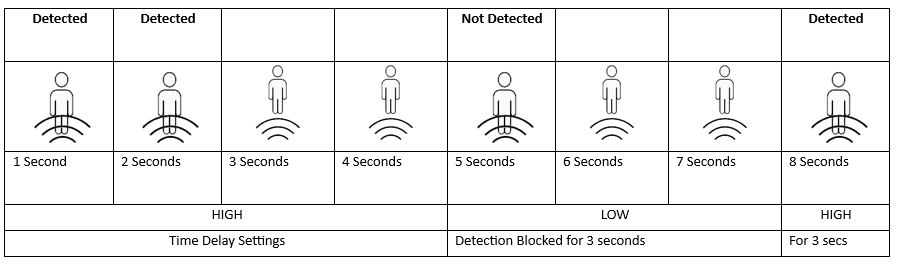
- Multiple Trigger Mode (H): Triggers series of motions. The time delay potentiometer determines how long the pin will stay
HIGH. In multiple trigger mode, the time delay is reset each time motion is detected, so there is no blocking of further detection.
Example: The time delay is 3 seconds. After motion is detected, the time delay period restarts. However, detection is still blocked for 3 seconds after the time delay expires. This 3-second delay allows the sensor to rest before starting to detect motion again..
Wiring
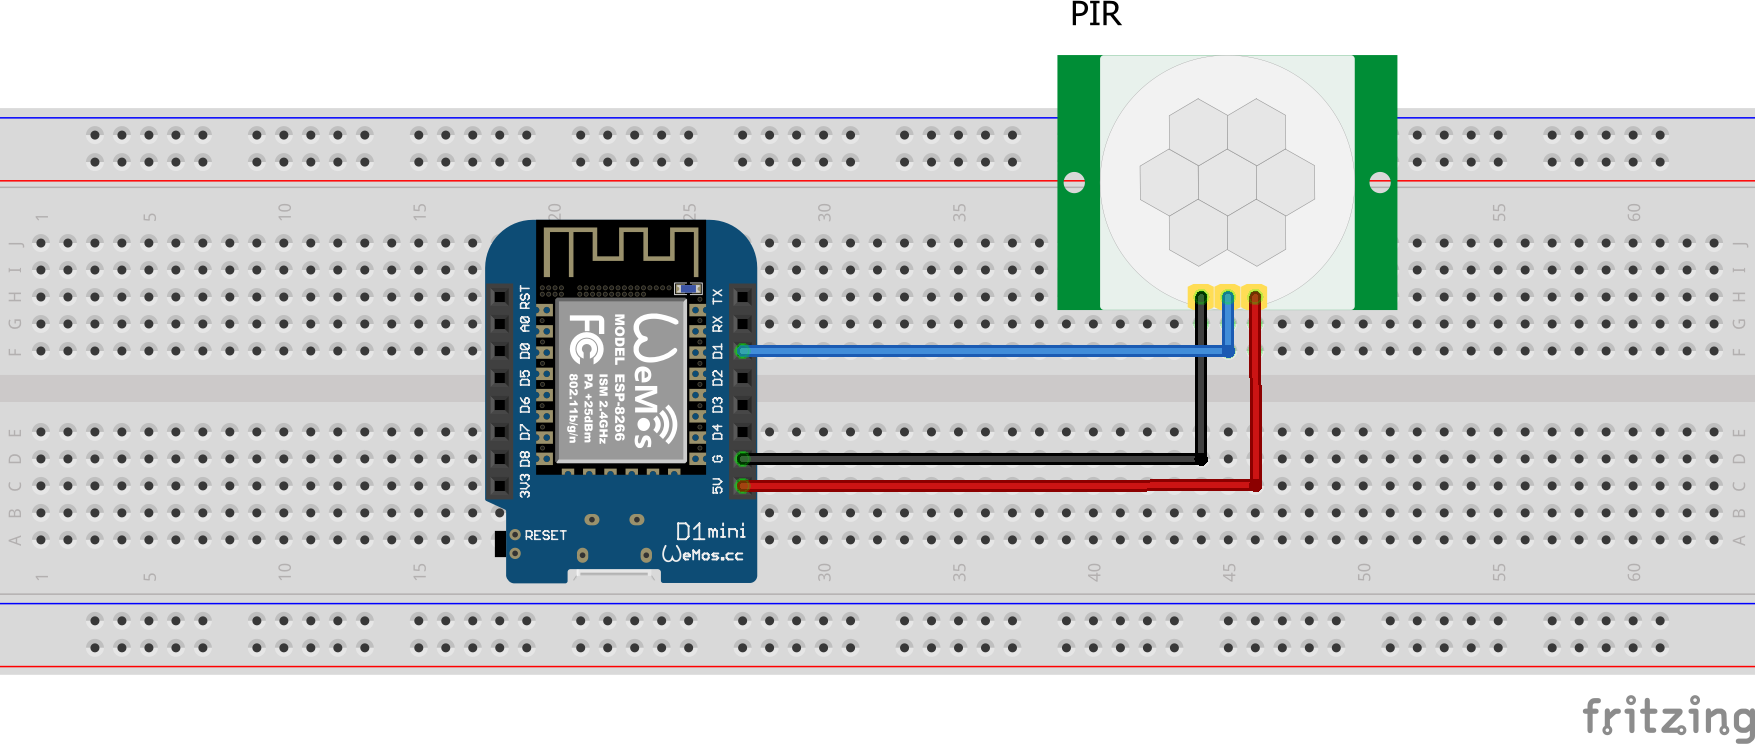
| MCU | PIR Pin |
|---|---|
| ESP32 | 16 |
| ESP8266 | 5 (D1) |
| Pico W | GP5 |
Let’s verify that motion sensor is wired correctly and working.
#if defined(ESP8266)
  #define SENSOR_PIN        D1
#elif defined(ESP32)
  #define SENSOR_PIN        26
#elif (ARDUINO_ARCH_RP2040)
  #define SENSOR_PIN        5
#endif

int newState;
int oldState;

void setup() {
  Serial.begin(9600);
  pinMode(SENSOR_PIN, INPUT);

  Serial.printf("Wait 10 secs for the PIR sensor to calibrate properly\r\n");
  delay(1000 * 10);
  oldState = digitalRead(SENSOR_PIN); // read the starting state
}

void loop() {
  newState = digitalRead(SENSOR_PIN); // read current state

  if(oldState != newState) {
    if (newState == HIGH) {
      Serial.println("Movement detected!");
    } else {
      Serial.println("Movement not detected!");
    }
    oldState = newState;
  }
   delay(100);
}
Arduino IDE Serial Monitor will show the motion detections like this:
Step 1 : Create a new device in Sinric Pro
- Login to your Sinric Pro account, go to Devices menu on your left and click Add Device button (On top left).
- Enter the device name Motion Sensor, description My Motion Sensor and select the device type as Motion Sensor.
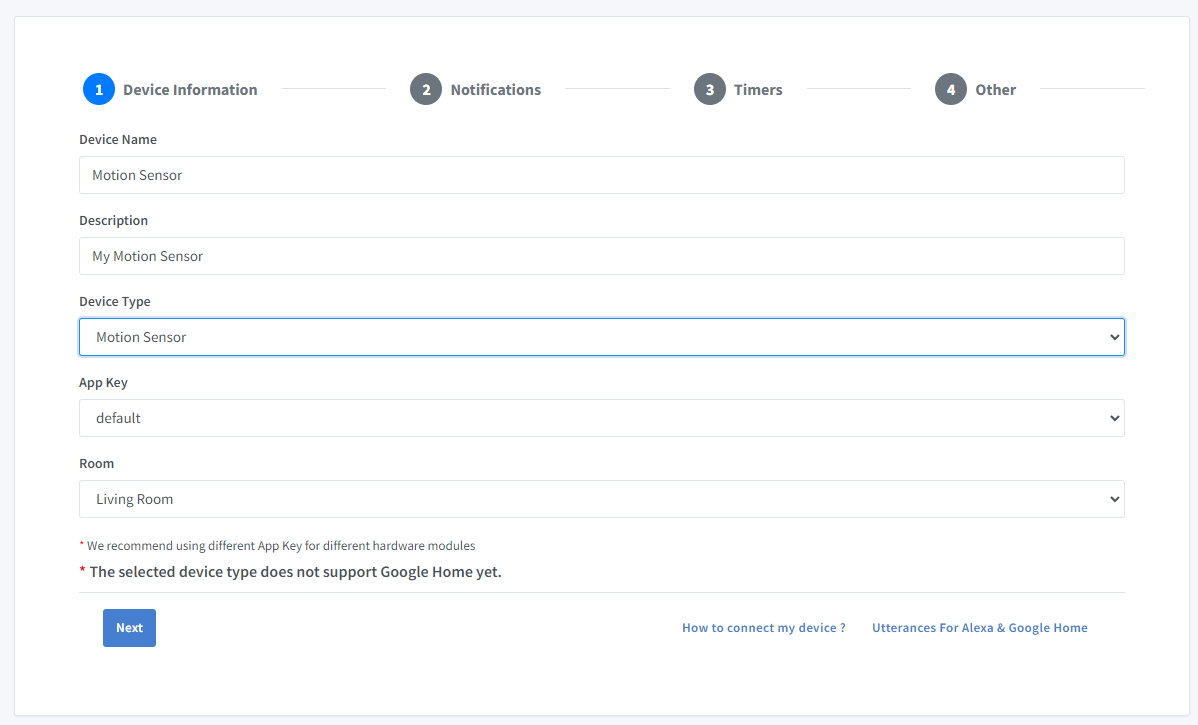
- Click Next the in the Notifications tab
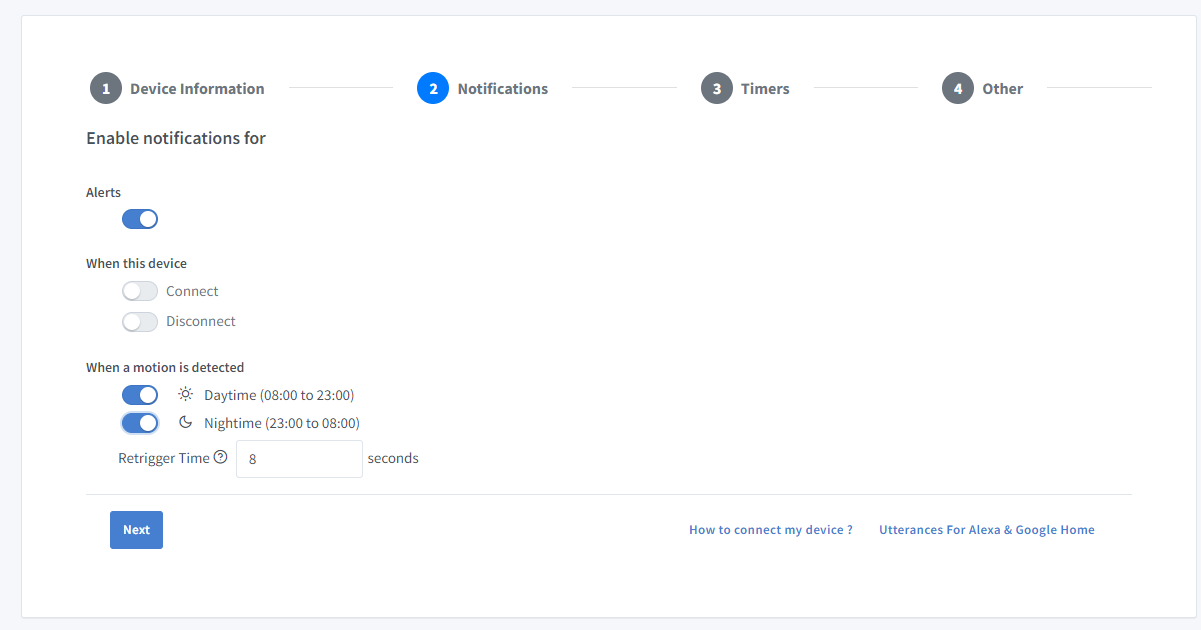
You can set the threshold here to receive a push notification via the Sinric Pro app when the motion is detected at Daytime or Nighttime. Use the Retrigger Time to set the delay between push notifications.
-
Click Others tab and Click Save
-
Next screen will show the credentials required to connect the device you just created.

- Copy the Device Id, App Key and App Secret Keep these values secure. DO NOT SHARE THEM ON PUBLIC FORUMS !
Step 2 : Connect to Sinric Pro
Step 2.1 Install Sinric Pro Library

You can generate the code using Zero Code feature or write it by your self. If you do not have programming experice, we recommend to use Zero Code feature in the Portal to generate the code, download and flash.
2.2 Complete Code
// Uncomment the following line to enable serial debug output
//#define ENABLE_DEBUG

#ifdef ENABLE_DEBUG
  #define DEBUG_ESP_PORT Serial
  #define NODEBUG_WEBSOCKETS
  #define NDEBUG
#endif

#include <Arduino.h>
#if defined(ESP8266)
  #include <ESP8266WiFi.h>
#elif defined(ESP32) || defined(ARDUINO_ARCH_RP2040)
  #include <WiFi.h>
#endif

#include "SinricPro.h"
#include "SinricProMotionsensor.h"

#define WIFI_SSID         ""   // Your WiFI SSID name
#define WIFI_PASS         ""   // Your WiFi Password.
#define APP_KEY           ""   // Should look like "de0bxxxx-1x3x-4x3x-ax2x-5dabxxxxxxxx" (Get it from Portal -> Secrets)
#define APP_SECRET        ""   // Should look like "5f36xxxx-x3x7-4x3x-xexe-e86724a9xxxx-4c4axxxx-3x3x-x5xe-x9x3-333d65xxxxxx" (Get it from Portal -> Secrets)
#define MOTION_SENSOR_ID  ""   // Should look like "5dc1564130xxxxxxxxxxxxxx" (Get it from Portal -> Devices)
#define BAUD_RATE         115200              // Change baudrate to your need (used for serial monitor)

#if defined(ESP8266)
  #define SENSOR_PIN        D1
#elif defined(ESP32)
  #define SENSOR_PIN        26
#elif (ARDUINO_ARCH_RP2040)
  #define SENSOR_PIN        5
#endif

int newState;
int oldState;

void handleMotionSensor() {
  newState = digitalRead(SENSOR_PIN); // read current state

  if(oldState != newState) {
    if (newState == HIGH) {
      Serial.println("Movement detected!");
    } else {
      Serial.println("Movement not detected!");
    }

    // newState == true (HIGH) : if motion has been detected
    // newState == false (LOW): if no motion has been detected

    SinricProMotionsensor &myMotionsensor = SinricPro[MOTION_SENSOR_ID]; // get motion sensor device
    myMotionsensor.sendMotionEvent(newState);

    oldState = newState;
  }
}


// setup function for WiFi connection
void setupWiFi() {
  Serial.printf("\r\n[Wifi]: Connecting");

  #if defined(ESP8266)
    WiFi.setSleepMode(WIFI_NONE_SLEEP);
    WiFi.setAutoReconnect(true);
  #elif defined(ESP32)
    WiFi.setSleep(false);
    WiFi.setAutoReconnect(true);
  #endif

  WiFi.begin(WIFI_SSID, WIFI_PASS);

  while (WiFi.status() != WL_CONNECTED) {
    Serial.printf(".");
    delay(250);
  }
  IPAddress localIP = WiFi.localIP();
  Serial.printf("connected!\r\n[WiFi]: IP-Address is %d.%d.%d.%d\r\n", localIP[0], localIP[1], localIP[2], localIP[3]);
}

// setup function for SinricPro
void setupSinricPro() {
  // add device to SinricPro
  SinricProMotionsensor &mySensor = SinricPro[MOTION_SENSOR_ID];

  // setup SinricPro
  SinricPro.onConnected([](){ Serial.printf("Connected to SinricPro\r\n"); });
  SinricPro.onDisconnected([](){ Serial.printf("Disconnected from SinricPro\r\n"); });
  //SinricPro.restoreDeviceStates(true); // Uncomment to restore the last known state from the server.
  SinricPro.begin(APP_KEY, APP_SECRET);
}

void setupMotionSensor() {
  pinMode(SENSOR_PIN, INPUT);
  Serial.printf("Wait 10 secs for the PIR sensor to calibrate properly\r\n");
  delay(1000 * 10);
}

// main setup function
void setup() {
  Serial.begin(BAUD_RATE); Serial.printf("\r\n\r\n");

  setupMotionSensor();
  setupWiFi();
  setupSinricPro();
}

void loop() {
  SinricPro.handle();
  handleMotionSensor();
}
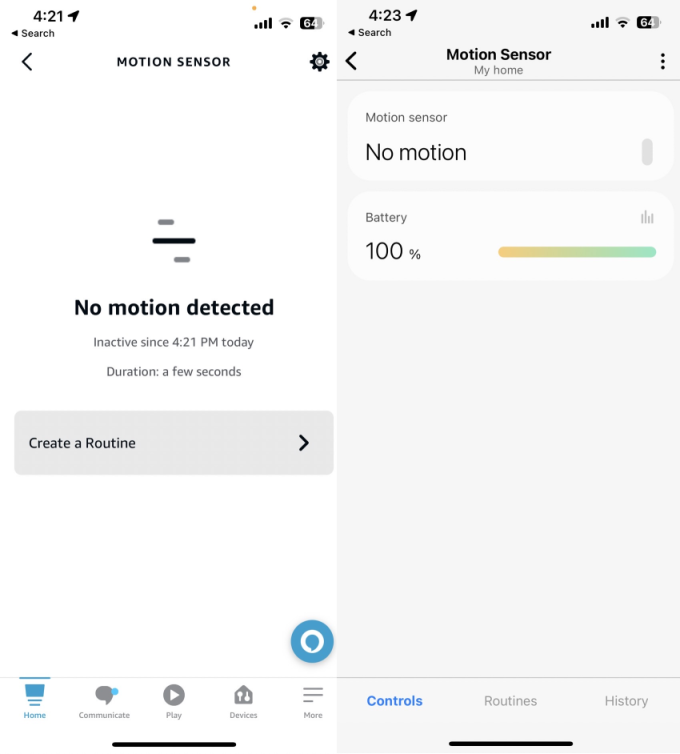
Now you should be able to view the motions via Alexa, SmartThings
via Portal
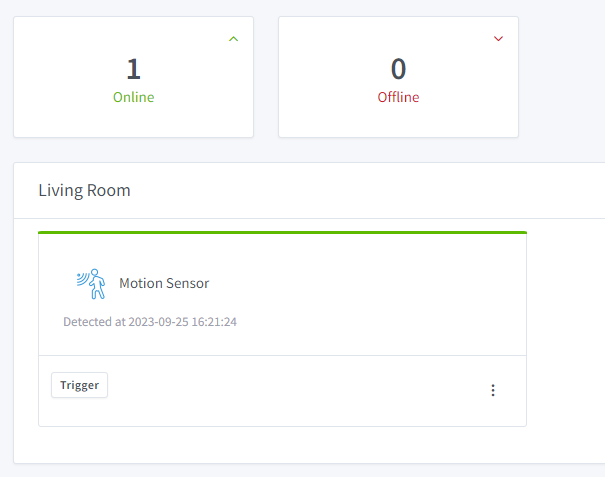
Please note that Google Home not supported.
Troubleshooting
- Please refer to our Troubleshooting page for more details.
Related tutorials
- How to control an ESP32 or ESP8266 with Alexa and Google Home
- Door and window contact sensor
- Smart doorbell
- Send announcements to Alexa
This document is open source. See a typo? Please create an issue